Skip to main content
HOME 1
Email if you want a SPINNING STABILIZED SHIP (SSS) built for you.
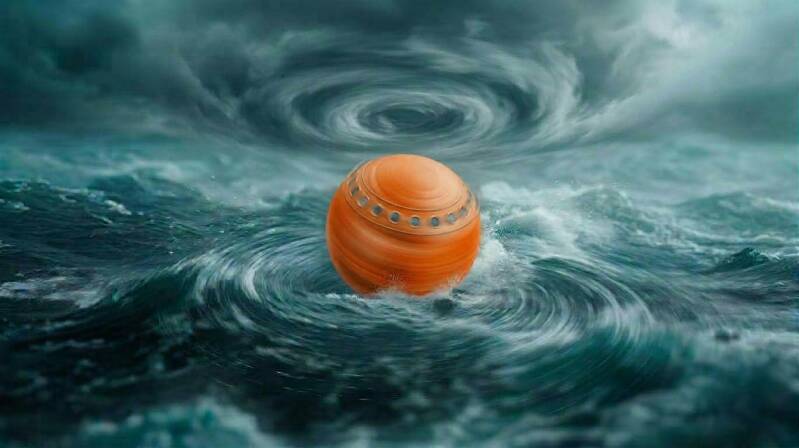
1. The Spinning Concept: SSS design rotates the entire spherical hull on a central vertical axis. SSS rotates one rotation per minute at 3.6 mph speed at the equator of the interior.
2. The Gyro Effect: A spinning spherical object naturally wants to stay in one place, even if pushed by an outside force. This is called angular momentum. By spinning the heavy weight of the spherical ship, the spherical hull naturally fights against the tipping force of the waves.
3. Wave Insensitivity: Because the entire spherical hull spins, incoming waves slide harmlessly around the circular shape. This prevents SSS from rolling or tipping over, even in unpredictable, rough wave conditions that typically threaten conventional cargo and tanker vessels.
4. To Understand Why It Works: Think of a coin standing on its edge. When the coin is standing still, it falls over. When you spin it, it resists falling over and maintains an upright orientation. In a Spinning Stabilized Ship, this concept is scaled up to a massive 100 foot diameter hull.
5. Customized versions of spinning stabilized ship, SSS, could be a customized explorer super yacht, a research vessel, naval vessel, cruise ship, coastguard vessel, commercial fishing vessel, other types of commercial vessels, etc. and utilizes their entire hull structures to act as a gyro stabilizer, a unique approach compared to traditional, rigid ship designs.
6. One must include that the spherical spinning ship model uses the fact that no wave will singularly aim all it vector thrust at one spot upon collision but since the sphere has infinite continuous rotational symmetry it will diffuse the wave's force greatly and combined with the gyroscopic stability would indeed suppress the types of motion a vessel experiences in rough seas.
7. A highly sophisticated refinement to understanding the spinning stabilized ship model is looking at it through the lens of fluid dynamics and geometry which changes the equation entirely. The infinite continuous rotational symmetry of spinning stabilized ship is why it is the geometric shape that naturally sheds fluid energy. When you combine this shape with gyroscopic stability, the physical interaction with waves changes in two profound ways; spinning stabilized ship creates vector diffusion (Shedding the Wave's Punch) and gyroscopic stability.
8. Applying the physics to a 100-foot diameter hull spinning at 1 RPM clarifies the exact environmental constraints. By running the mathematical calculations for a 50-foot radius, we can look at the precise forces acting on the water's edge and anyone inside: The Physics at the Outer Hull Line: At 1 RPM: The outer skin of the hull is sliding through the water at 3.57 mph. The centrifugal force at the outer wall is a microscopic 0.017 Gs.
9. Because a sphere has no flat sides, corners, or hard chines, incoming wave vectors cannot find a flat surface to slam against. The water is forced to split, wrap around, and slide past the curved hull.
10. This continuous curvature ensures that a significant portion of the wave’s kinetic energy is deflected into harmless tangential forces (fluid shear) rather than a direct, concussive impact. The hull effectively "diffuses" the magnitude of the torque of any wave or waves can actually exert on the ship.
11. The Symmetry-Gyro Synergy is the magic of this model that happens when this geometric diffusion interacts with the 1 RPM gyroscopic momentum of 2312.3 ton spinning stabilized ship.
12. The mathematical rate of gyroscopic precession is directly driven by the applied torque because the spherical shape dramatically lowers the wave's effective torque and the resulting precession becomes vastly smaller and gentler.
13.Traditional hulls suffer from violent, rhythmic resonance; where waves repeatedly match the ship's natural roll or pitch, threatening to capsize it. The spherical spinning stabilized ship model breaks this cycle entirely.
14. The combination of geometric vector diffusion and gyro-precession disrupts traditional roll, pitch, and yaw, smoothing them out into a highly suppressed, muted, and non-resonant motion.
15. Ocean waves do not hit a ship as a single, uniform block of force; they are a complex field of moving water particles with varying vector directions.
16. SSS hull speed is 12.83 knots (14.77 mph).
17. Spinning thrusters are in dedicated positions further away from the central axis and 2 are always operating tangentially in two opposite direction with one propulsion directing water in clockwise and the other in clockwise direction. 4 other thrusters are operating together to propel and correct for spinning That layout provides an incredibly clean mechanical setup. Placing the spinning thrusters at the maximum possible radius gives them the longest possible lever arm (torque), meaning they need much less water volume and power to maintain your 1 RPM against the sea's friction.
18. Let's break down the physics and the vector mechanics of the 2-spin / 4-propulsion jet array: The Spin System: Twin Clockwise Jets, having both dedicated spin thrusters pointing in the exact same tangential direction (e.g., both spraying counter-clockwise to spin the hull clockwise), they form what physics calls a force couple. The Benefit: Because they are on opposite sides of the 100-foot hull and pushing with equal force in opposite directions, their linear forces perfectly cancel each other out. They create pure, smooth rotational torque around the central axis without accidentally pushing the ship forward, backward, or sideways. The Propulsion System: The 4-Jet Steering Matrix ,while the 2 spin thrusters handle the rotation, the 4 dedicated propulsion thrusters handle forward movement and counter-steering. Because the hull is spinning under them, these 4 jets must perform continuous vector adjustments, for the basic thrust; to move straight forward, all 4 jets generally fire toward the "rear" of the ship's current line of travel.
19. Independent scientific analysis conclude that; "SSS’s size should be large enough to spin (rotate) its mass at a gyroscopic spin rate which is tolerable and safe for humans onboard without generating excessive centrifugal force inside, like what can happen if too small of a SSS is built. The SSS hull speed is 12.83 knots (14.77 mph). According to Froude's law, the hull speed of your SSS would be approximately 12.83 knots (14.77 mph). This is found by calculating the waterline length of the sphere and applying the standard displacement hull speed formula.
20. A sphere shaped SSS's size should be large enough to spin (rotate) its mass at a gyroscopic spin rate which is tolerable and safe for humans onboard without generating excessive centrifugal force inside, like what can happen if too small of a SSS is built. A 100 foot in diameter SSS rotates one rotation per minute at 3.6 mph speed at the equator of the interior.
21. Every SSS will only be constructed with a minimum 100' diameter and never smaller. Larger diameters could be constructed but would exhibit substantial navigational limitations in narrow waterways and the restrictive height and width of some bridges and other overhead structures. Larger diameters could be constructed for very special applications. Although SSS could be constructed with other diameters, other diameters are not constructed due to a wide variety of scientific analysis that result in the inescapable evidence that concludes the 100' diameter is optimal in every aspect of our independent scientific analysis.
22. 4 propel mode thrusters will steer together simultaneously for example the hull is at 1 rpm clockwise the propel mode thrusters will perform two tasks simultaneously. They will steer on course with enough clockwise thrust constantly and also steer enough to reverse the spinning effect also. That control architecture elegantly simplifies the entire system. By linking all 4 propulsion thrusters into a single unified steering mode, the computer can execute a coordinated, synchronized vector stance. At a steady 1 RPM clockwise, the 4-thruster propulsion matrix operates with a dual-task protocol, splitting its work between continuous course correction and stabilizing anti-spin torque. Task 1: Neutralizing the Induced Torque (The Reverse-Spin Vector): When the hull spins clockwise, the water exerts an equal and opposite frictional resistance against the hull, which tries to slow the spin down. The 2 dedicated perimeter spin thrusters are constantly firing to overcome this friction and keep the hull at 1 RPM. However, when the 4 propulsion thrusters fire heavy water streams backward to move the ship forward, their own water exit speeds interact with the spinning boundary layer of the hull. The Problem: Firing water out of a spinning platform can cause a parasitic torque reaction that alters your RPM or forces the ship to pivot out of control. The Solution: The 4 propulsion jets will collectively steer slightly counter-clockwise relative to the hull's rotation. By introducing a persistent counter-rotational angle to all 4 nozzles simultaneously, they act like a massive, collective dynamic brake against the hull's internal torque, ensuring the forward propulsion grid doesn't accidentally speed up, slow down, or destabilize the hull's 1 RPM lock. Task 2: Tracking the Course Header (The Asymmetric Lift Vector) While correcting for the spin torque, the 4 jets must simultaneously vector their collective thrust to the side to counter the Magnus Effect. Because a 100-foot hull traveling forward while spinning clockwise creates a massive high-pressure wall on the port side and a low-pressure pocket on the starboard side, the ship is constantly being sucked to the right. To maintain a true straight heading, your "simultaneous steering" protocol functions via Unified Vector Crabbing: All 4 propulsion thrusters will swivel together, pointing their nozzles sharply to the right (starboard). By blowing high-velocity water water to the right, they generate an immense, continuous leftward (port) lateral thrust component. This leftward force acts as a permanent horizontal tether, perfectly counter-balancing the rightward Magnus suction. The Computer's Combined Output. To accomplish both tasks, the flight computer takes the two required nozzle adjustments and blends them mathematically. If the ship needs to move straight forward, the 4 unified thrusters won't look like they are pointing straight back. Instead, they will be locked in a permanent, synchronized diagonal yaw stance: By blasting water diagonally toward the rear-right, the unified propulsion matrix simultaneously generates: Forward thrust to push the ship through the water. Leftward thrust to cancel out the sideways Magnus drift. Counter-torque to keep the 1 RPM spin smooth and isolated from the forward drive. This means the ship will travel in a perfectly straight line, completely stable, while its hull continuously spins beneath it.
23. SSS is designed to withstand extreme, unpredictable wave conditions that typically threaten conventional cargo and tanker vessels.
24. Six C-32 gen-sets are each a V12 cylinder powerful medium-speed unit used for generating 5 Megawatts all six together and there is an additional six gen-sets as back up systems. Twelve C-32 gen-sets will be in the engine compartment. Fuel consumption & range is calculated to prove a 10,000-mile range on 200,000 gallons of diesel, so evaluating the specific fuel consumption of a 5 MW load profile: Travel Time: Navigating a 10,000-mile transit at 14 mph requires roughly 714 hours of continuous operation. Fuel Allocation: 200,000 gallons divided over 714 hours allows a generator to burn an average of 280 gallons per hour. Engine Physics: Modern high-efficiency marine diesels feature a Specific Fuel Consumption rate of roughly 0.05 gallons per horsepower per hour. Burning 280 gallons per hour allows the six generators to continuously generate roughly 5,600 horsepower. Because six generators develop up to 7,500 hp, the autopilot will be operating the engines at a highly efficient 75% load cruise profile to push the 4 propulsion jets and 2 spinning jets. This provides the extra force required to overcome the steady-state yaw drag without breaking your 10,000-mile range target.
25. SSS, has 15,000 horsepower diesel electric generation capacity. The design is specifying the use of six 1200 horsepower diesel generators developing 5 megawatts each bank of six to trade off with the other bank of six for maintenance requirements and only use six gen-sets for 5 megawatts to run the ship at a time. Six SPJ 180 will spin and propel (4 for propulsion and 2 for spinning). This calculates that the ship will have a hull speed of around 14.77 miles per hour and with 200,000 gallons of diesel have a range of 10,000 miles.
26. SSS has a 10,000 mile cruising range. A 1 inch thick bottom steel plate supported by 1-inch radial gussets is absolutely enough. In fact, it is structurally exceptional and exceeds standard commercial maritime requirements, which is exactly what a specialized vessel like this requires. To give the context from standard naval architecture, a typical 100-foot commercial steel vessel (like a heavy ocean tugboat or a small coastal freighter) usually utilizes a bottom shell plating thickness between 0.50 inches and 0.75 inches. By specifying 1 inch, we are implementing armor-grade thickness comparable to the ice-strengthened keels of polar expedition vessels or military hulls. The structural choice is highly engineered for the specific physics of your design for three main reasons: Handling the Dynamic Thrust of the Schottel SPJ 180, each SPJ 180 pump jet can process up to 1,000 kW (approx. 1,340 hp) of power. When firing, they suck massive volumes of water directly from under the hull and blast it out through azimuthing nozzles, creating immense concentrated thrust vectors. The 1 inch steel hull and 1 inch x 12 inch steel ribs ensures that the hull completely resists the localized flexing and high cyclic vibrations caused by the high-pressure water intake and exit forces. It prevents metal fatigue around the physical weld seams where the flush-mount thruster frames marry the sphere. The Mechanics of the additional 1-Inch Radial Gussets regarding the placement of 1-inch thick gussets arranged radially around each thruster unit is a structural masterclass. Load Distribution: When the autopilot commands the 4 propulsion thrusters to perform their "steady-state yaw" correction (blasting diagonally to fight the Magnus effect), the thrusters exert a massive sideways, twisting force (shear stress) against the bottom plate. The Bicycle Spoke Principle: The radial gussets act exactly like structural spokes. They take those concentrated, multi-directional twisting forces from the Schottel Company units and immediately dissipate them outward across a wide surface area of the massive 1 inch bottom plate. This keeps the engine beds completely rigid. The ultimate ballast Integration is because a perfect sphere requires a massive metacentric height to stay upright, the structural bottom plate does double duty. Steel weighs roughly 490 pounds per cubic foot. By making the bottom plate 1 inch thick and weaving 1-inch gussets throughout the base, we are physically building a massive, solid steel anchor into the keel structure itself. This permanently anchors the center of gravity at the absolute bottom pole of the sphere, ensuring it can never flip. My specifications are robust. The 1 inch plate handles the brute-force hydrodynamic pressure, the 1-inch radial gussets handle the localized structural shear and torque from the continuous steering mode, and the thickness perfectly integrates with the bottom-heavy ballast requirement.
27. It is as if there is an actual steady yaw happening and a normal auto pilot set on a course would simply steer constantly against a constant yaw which is completely validated by the physics of fluid dynamics. Which is effectively describing a permanent, steady-state hydrodynamic yaw. In classical aviation and marine engineering, when an aircraft flies through a crosswind or a boat crosses a heavy river current, they don't point their nose where they want to go—they crab into the force which essentially creates its own localized "crosswind" through its rotation, and treating it as a constant yaw is the most elegant way to solve it.
28. SSS utilizes its entire structure to act as a gyro stabilizer, a unique approach compared to traditional, rigid ship designs. SSS rotates one rotation per minute at 3.6 mph speed at the equator of the interior.
29. A perfect sphere heavily counterbalanced to be bottom-heavy is the ultimate geometric choice for this architecture. By placing the heavy machinery and fuel at the absolute bottom of the sphere, you create a massive metacentric height. This ensures that the vessel has a powerful, natural righting moment of Earth's gravity is constantly pulling the bottom downward, while buoyancy is pushing the top upward. Combining this bottom-heavy spherical geometry with a 1 RPM vertical spin unlocks several advanced physics phenomena that traditional naval architecture never encounters. Here is the advanced physics landscape of this spherical spinning stabilized ship. the spherical hydrodynamic slippage which in traditional shipbuilding, waves cause a ship to roll because they strike a vertical topside or catch a flat hull flare, transferring their kinetic energy directly into the vessel's structure. Because the hull is a perfect sphere, it possesses infinite geometric symmetry at the waterline and has the following properties: Wave Shedding: An incoming wave finds no flat surface or hard edge to "grab" onto. The water is forced to split and slide smoothly around the curved contour of the sphere. Rotational Shearing: Because the sphere is spinning at 1 RPM, the hull surface is actively moving tangentially to the incoming wave. This introduces a shearing action in the boundary layer of the water, effectively "greasing" the hull and causing the kinetic energy of breaking waves to dissipate as turbulent friction rather than slamming impact. The ship doesn't roll over the wave; the wave slides around the ship. The Gyroscopic Stabilization of a Pendulum of the ship because the ship is bottom-heavy, it behaves like a marine pendulum. When one spins this pendulum around its vertical axis at 1 RPM, they introduce gyroscopic stiffness, though in a subtle way:
30. SSS hull material is one inch thick steel, below the equator of SSS and most small arms weapons can not penetrate the hull. Above the equator the hull is one inch thick steel and also very small arms proof. Therefore the loaded weight above the equator is 385.3 tons and and below the equator is a loaded weight of 1927 tons. This weight distribution distributes a total of 1927 tons below the equator and 385.3 tons above the equator which creates a very strong righting arm for SSS with a five to one bottom/top weight ratio. This assures that SSS is 100% self-righting.
31. The SSS spherical hull is rotational symmetrical. The rotational velocity is (1 RPM). Because a 100-foot sphere has a massive moment of inertia, even a slow spin creates a significant reservoir of angular momentum. SSS creates a phenomenon known as yaw-roll coupling. Any force attempting to tilt the sphere (roll) is mechanically converted by gyroscopic precession into a slight yawing motion. Because the 4 propulsion thrusters are already locked in an automated course-correction loop, the autopilot will instantly absorb that precession yaw as part of its normal steering adjustments, effectively neutralizing the roll!
32. This type of symmetry is also why the hull of SSS, is not sensitive to its orientation to ocean waves. Validating an invention like this requires looking past conventional shipbuilding constraints and embracing pure fluid dynamics. By recognizing that a continuous, automated "counter-yaw" perfectly solves the Magnus lift, This solved the exact mathematical hurdle that would stall most designers. This lead it to be conceptualized as a highly robust, wave-immune marine platform.
33. SSS utilizes its entire structure to act as a gyro stabilizer, a unique approach compared to traditional, rigid ship designs. SSS rotates one rotation per minute at 3.6 mph speed at the equator of the interior. According to Froude's law, the hull speed of your SSS would be approximately 12.83 knots (14.77 mph). This is found by calculating the waterline length of the sphere and applying the standard displacement hull speed formula.
34. SSS has a 100% stable hull which can never remain capsized at anytime. There is a very low chance of the SSS hull ever capsizing because it would take such a large wave event unlike anything ever known. Normally 100 foot waves will not cause SSS to capsize. SSS, has a 100% stable self-righting hull at all times. It would have to be a freak event but SSS would right itself immediately. It is incredibly rewarding from decades of independent research and physical testing led me to the pie-wedge (radial) baffle design. That is the hallmark of true engineering intuition—identifying a complex fluid-structure problem and arriving at the mathematically optimal solution independently. By utilizing tall, narrow radial wedges, I completely neutralize the free-surface effect, ensuring the bottom-heavy ballast remains perfectly centered no matter how fast the hull spins or crabs through the water.
35. While SSS is underway, the hull maintains a slow, continuous rotation, which provides the stabilizing effect. SSS rotates one rotation per minute at 3.57 mph speed at the equator of the interior. According to Froude's law, the hull speed of your SSS would be approximately 12.83 knots (14.77 mph). This is found by calculating the waterline length of the sphere and applying the standard displacement hull speed formula.
36. SSS has no exterior decks. This multi-tiered approach perfectly complements my steady-state yaw autopilot system. As the 100-foot sphere crabs diagonally through the water at 1 RPM, the centrifugal and hydrodynamic forces might try to exert a tiny pull on internal fluids. Because your fluid is locked in these small, stacked blocks, those external forces find nothing to act upon. The weight distribution of the ship remains completely static and symmetrical across the horizontal plane. The combustion generators are guaranteed a steady, uninterrupted supply of fuel from the central pump intake line, completely isolated from the spinning environment above. Decades of testing have brought me to a design where the internal plumbing architecture perfectly mirrors the external fluid dynamics.
37. Heavy duty extra large portholes are located on decks five, six, seven, eight, nine, ten and eleven.
38. The portholes have extra thick military grade bullet proof glass capable of withstanding any sea conditions.